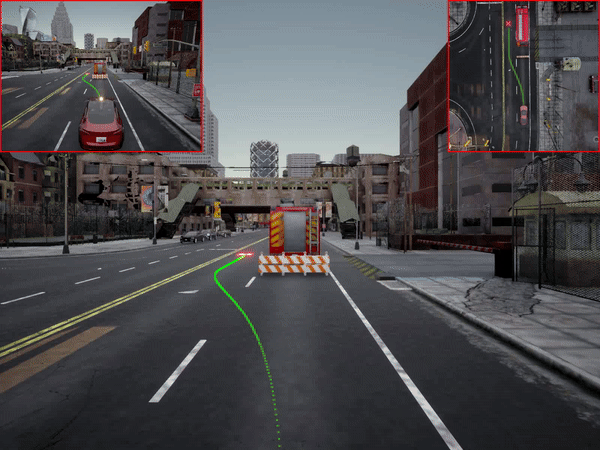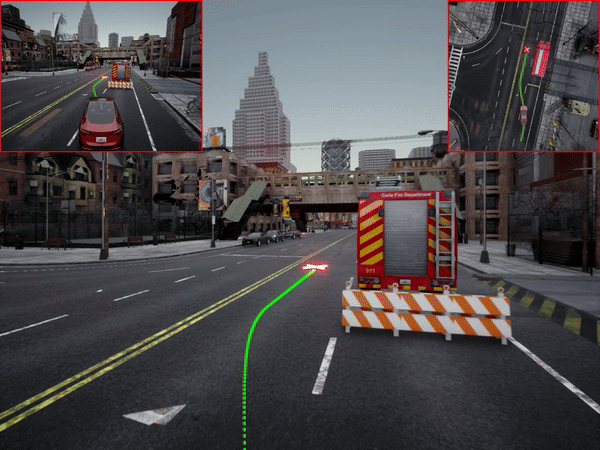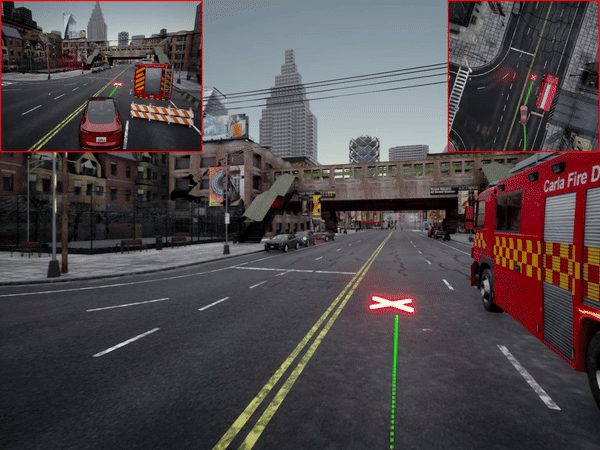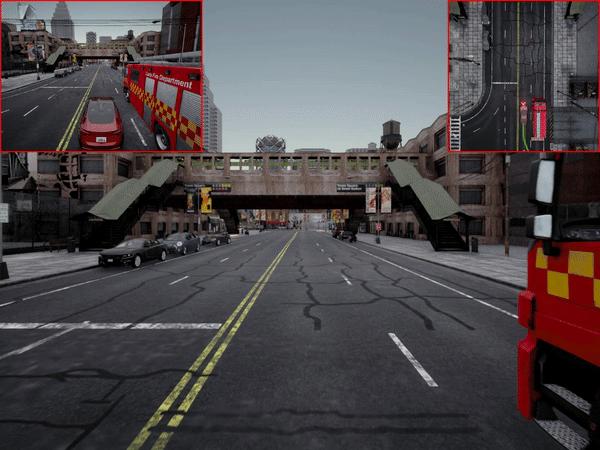
“Full self-driving is amazing- until it isn't.”
I am a PhD Researcher at the Robotics Research Center (RRC), IIIT Hyderabad, advised by Prof. K. Madhava Krishna and co-advised by Prof. Arun Kumar Singh.
My research focuses on combining learning-based and classical methods for motion planning and navigation. My early work explored jointly training perception and planning end-to-end to better align their objectives, an idea now reflected in many Vision-Language-Action (VLA) models. Building on this direction, I am currently exploring methods that augment generative trajectory planners with optimization-based solvers to enforce safety constraints by construction rather than through test-time refinement.
- Sep 2026Recognized as an Amazon AI100 Researcher, one of India’s Top 100 PhD researchers in AI/ML
- Jan 2026Teaching Assistant EC4.403: Robotics Planning and Navigation, Spring 2026
- Jan 2026MonoMPC accepted at IEEE RA-L 2026 (Presented at ICRA 2026)
- Oct 2025Presented SparseLoc and Diffusion-FS at IROS 2025, Hangzhou, China
- Oct 2024Presented LeGo-Drive at IROS 2024, Abu Dhabi, UAE
- Aug 2024Selected as a Qualcomm Innovation Fellowship Finalist, India
- May 2024Organized RRC Summer School, 2024
Selected PublicationsView all →
Reach me at:
- reachpranjal19 [at] gmail [dot] com
- For official purpose: pranjal.paul [at] research [dot] iiit [dot] ac [dot] in